Emergency Response Mobile Robot
Overview
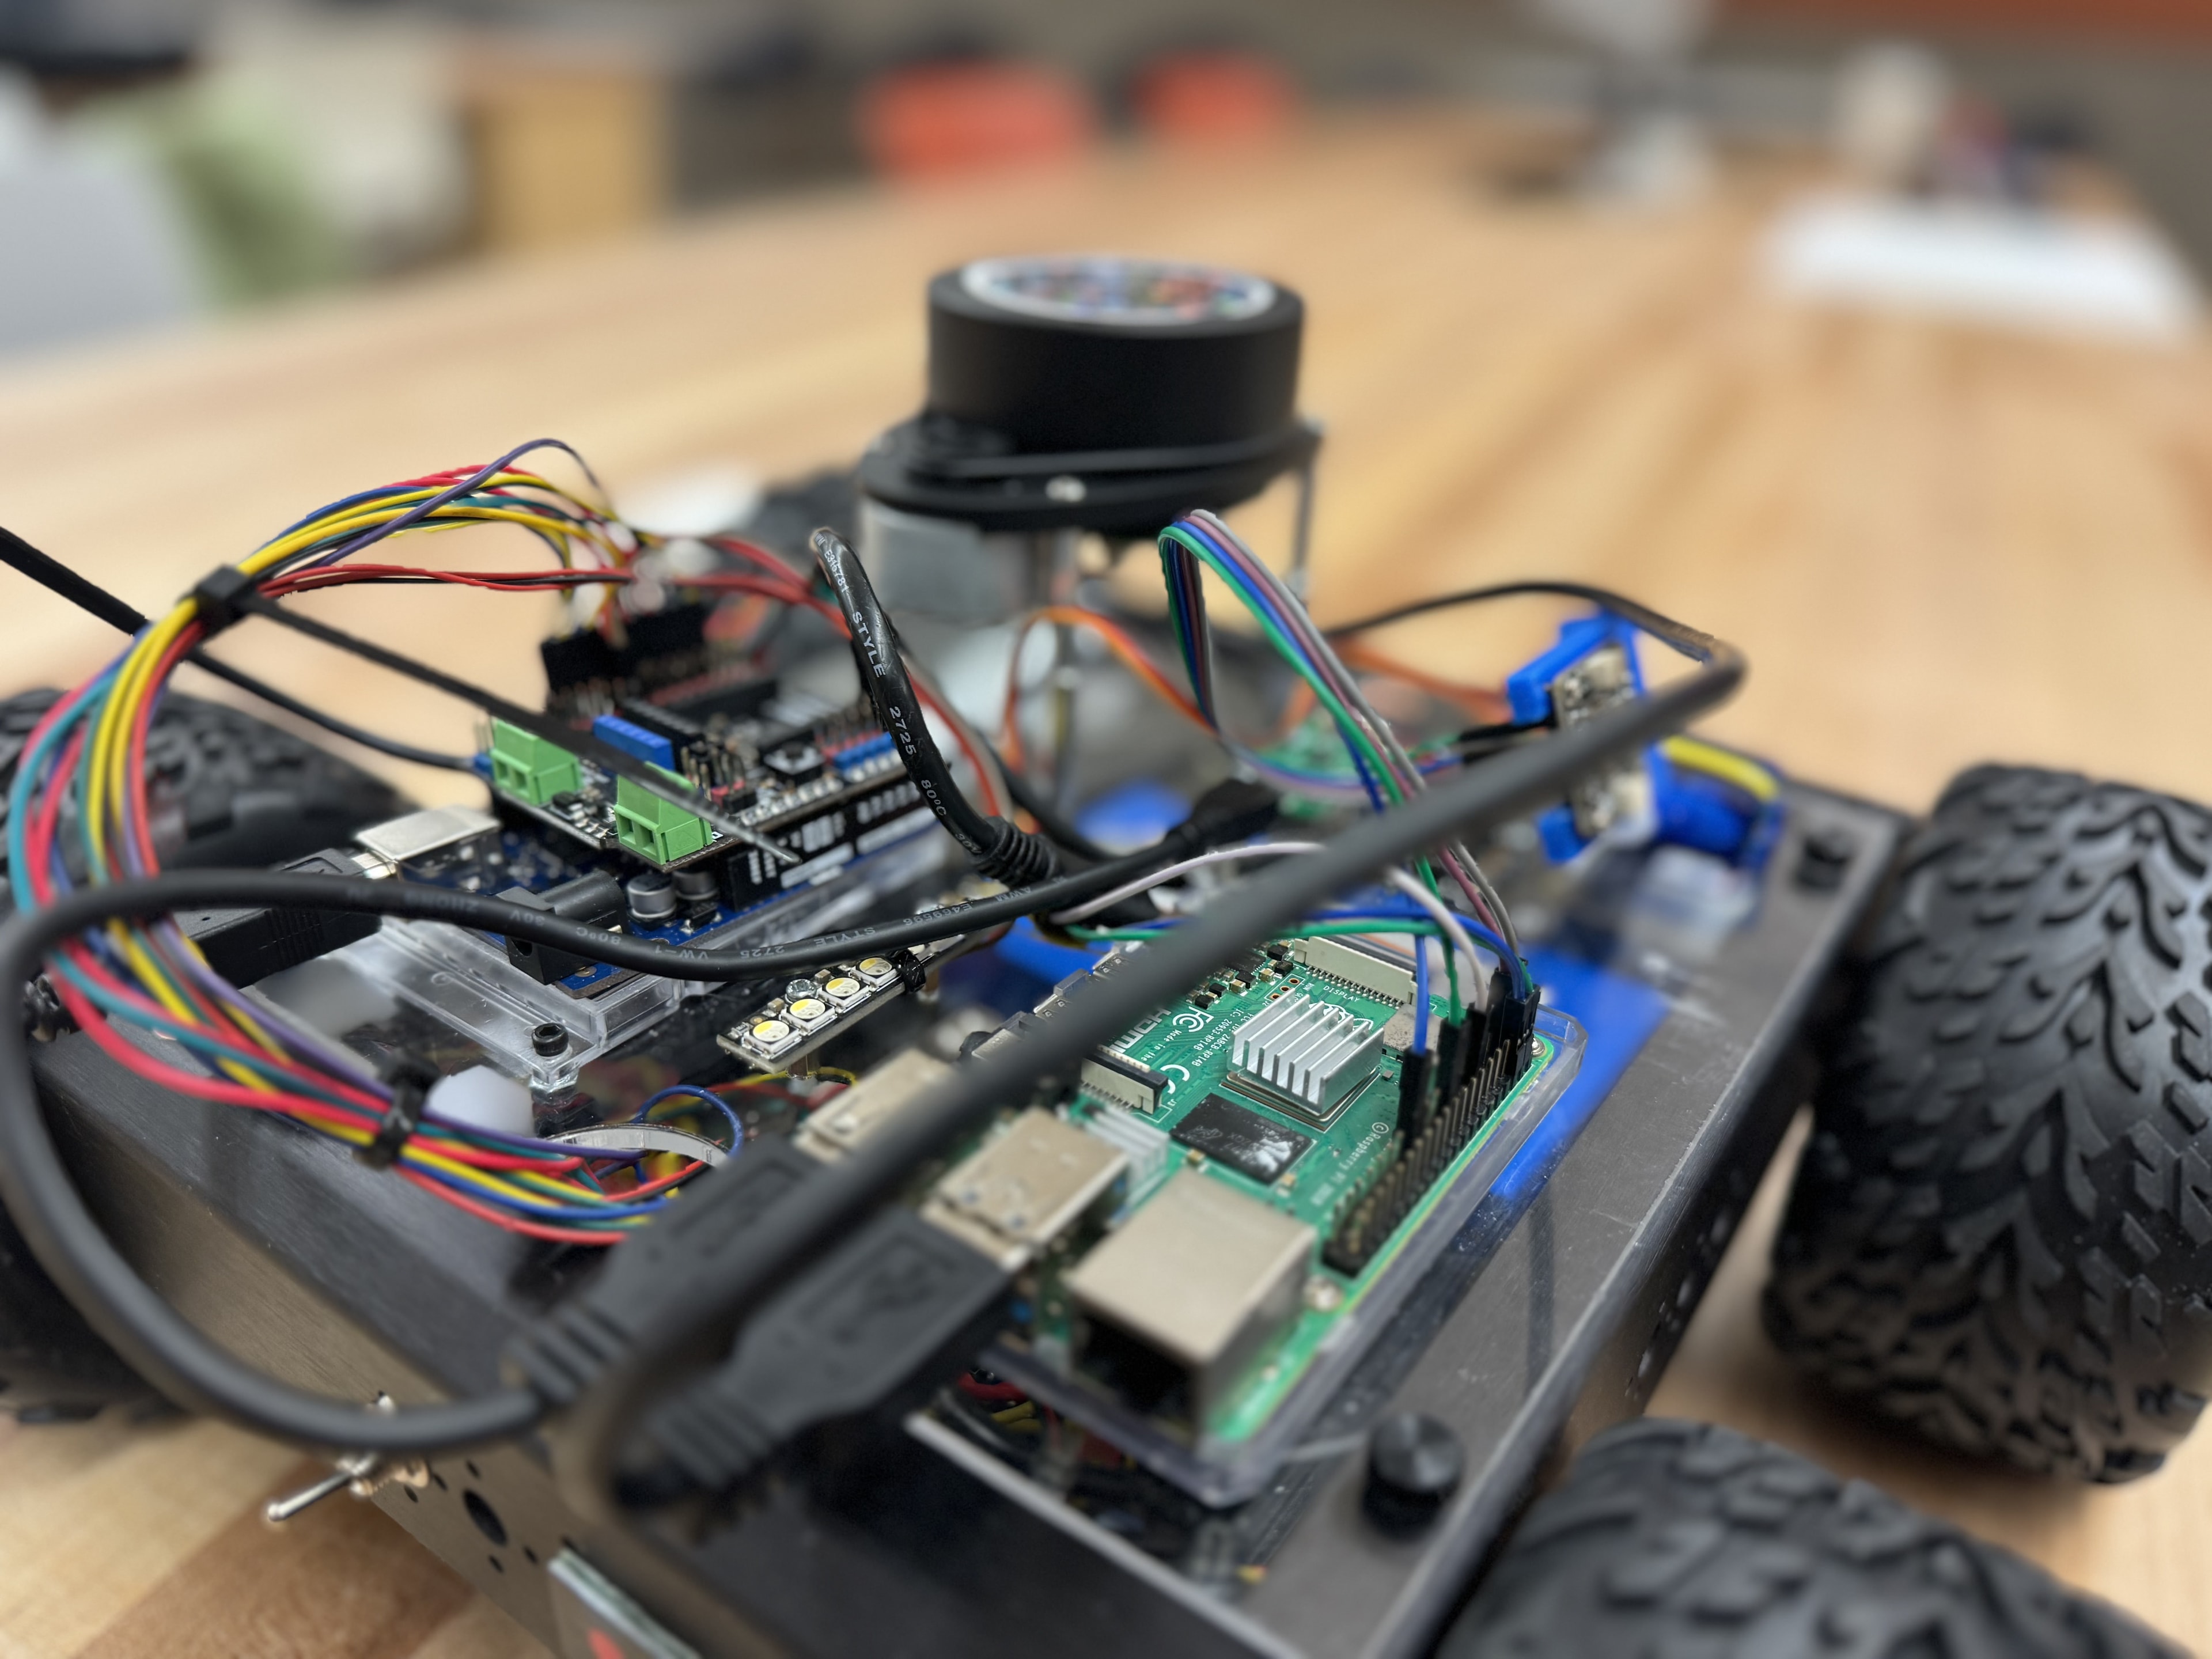
I led a team of fellow students to develop a prototype autonomous emergency response robot as part of a semester long project, utilizing ROS2, Arduino, Python, and C++. We applied what we learned in our courses to equip the robot with a thermal camera for heat spot detection, making it highly effective in emergency situations. To enhance its efficiency and safety, we incorporated LiDAR-based obstacle avoidance and a PID controller, directly applying theoretical knowledge to practical challenges. Additionally, we designed the mounts and system architecture using SOLIDWORKS and Miro. This project allowed us to bring together classroom concepts and real-world applications in a meaningful way.
Tech stack
PythonC++ROS2
 1 / 3