Line-Following Loader Robot
Overview
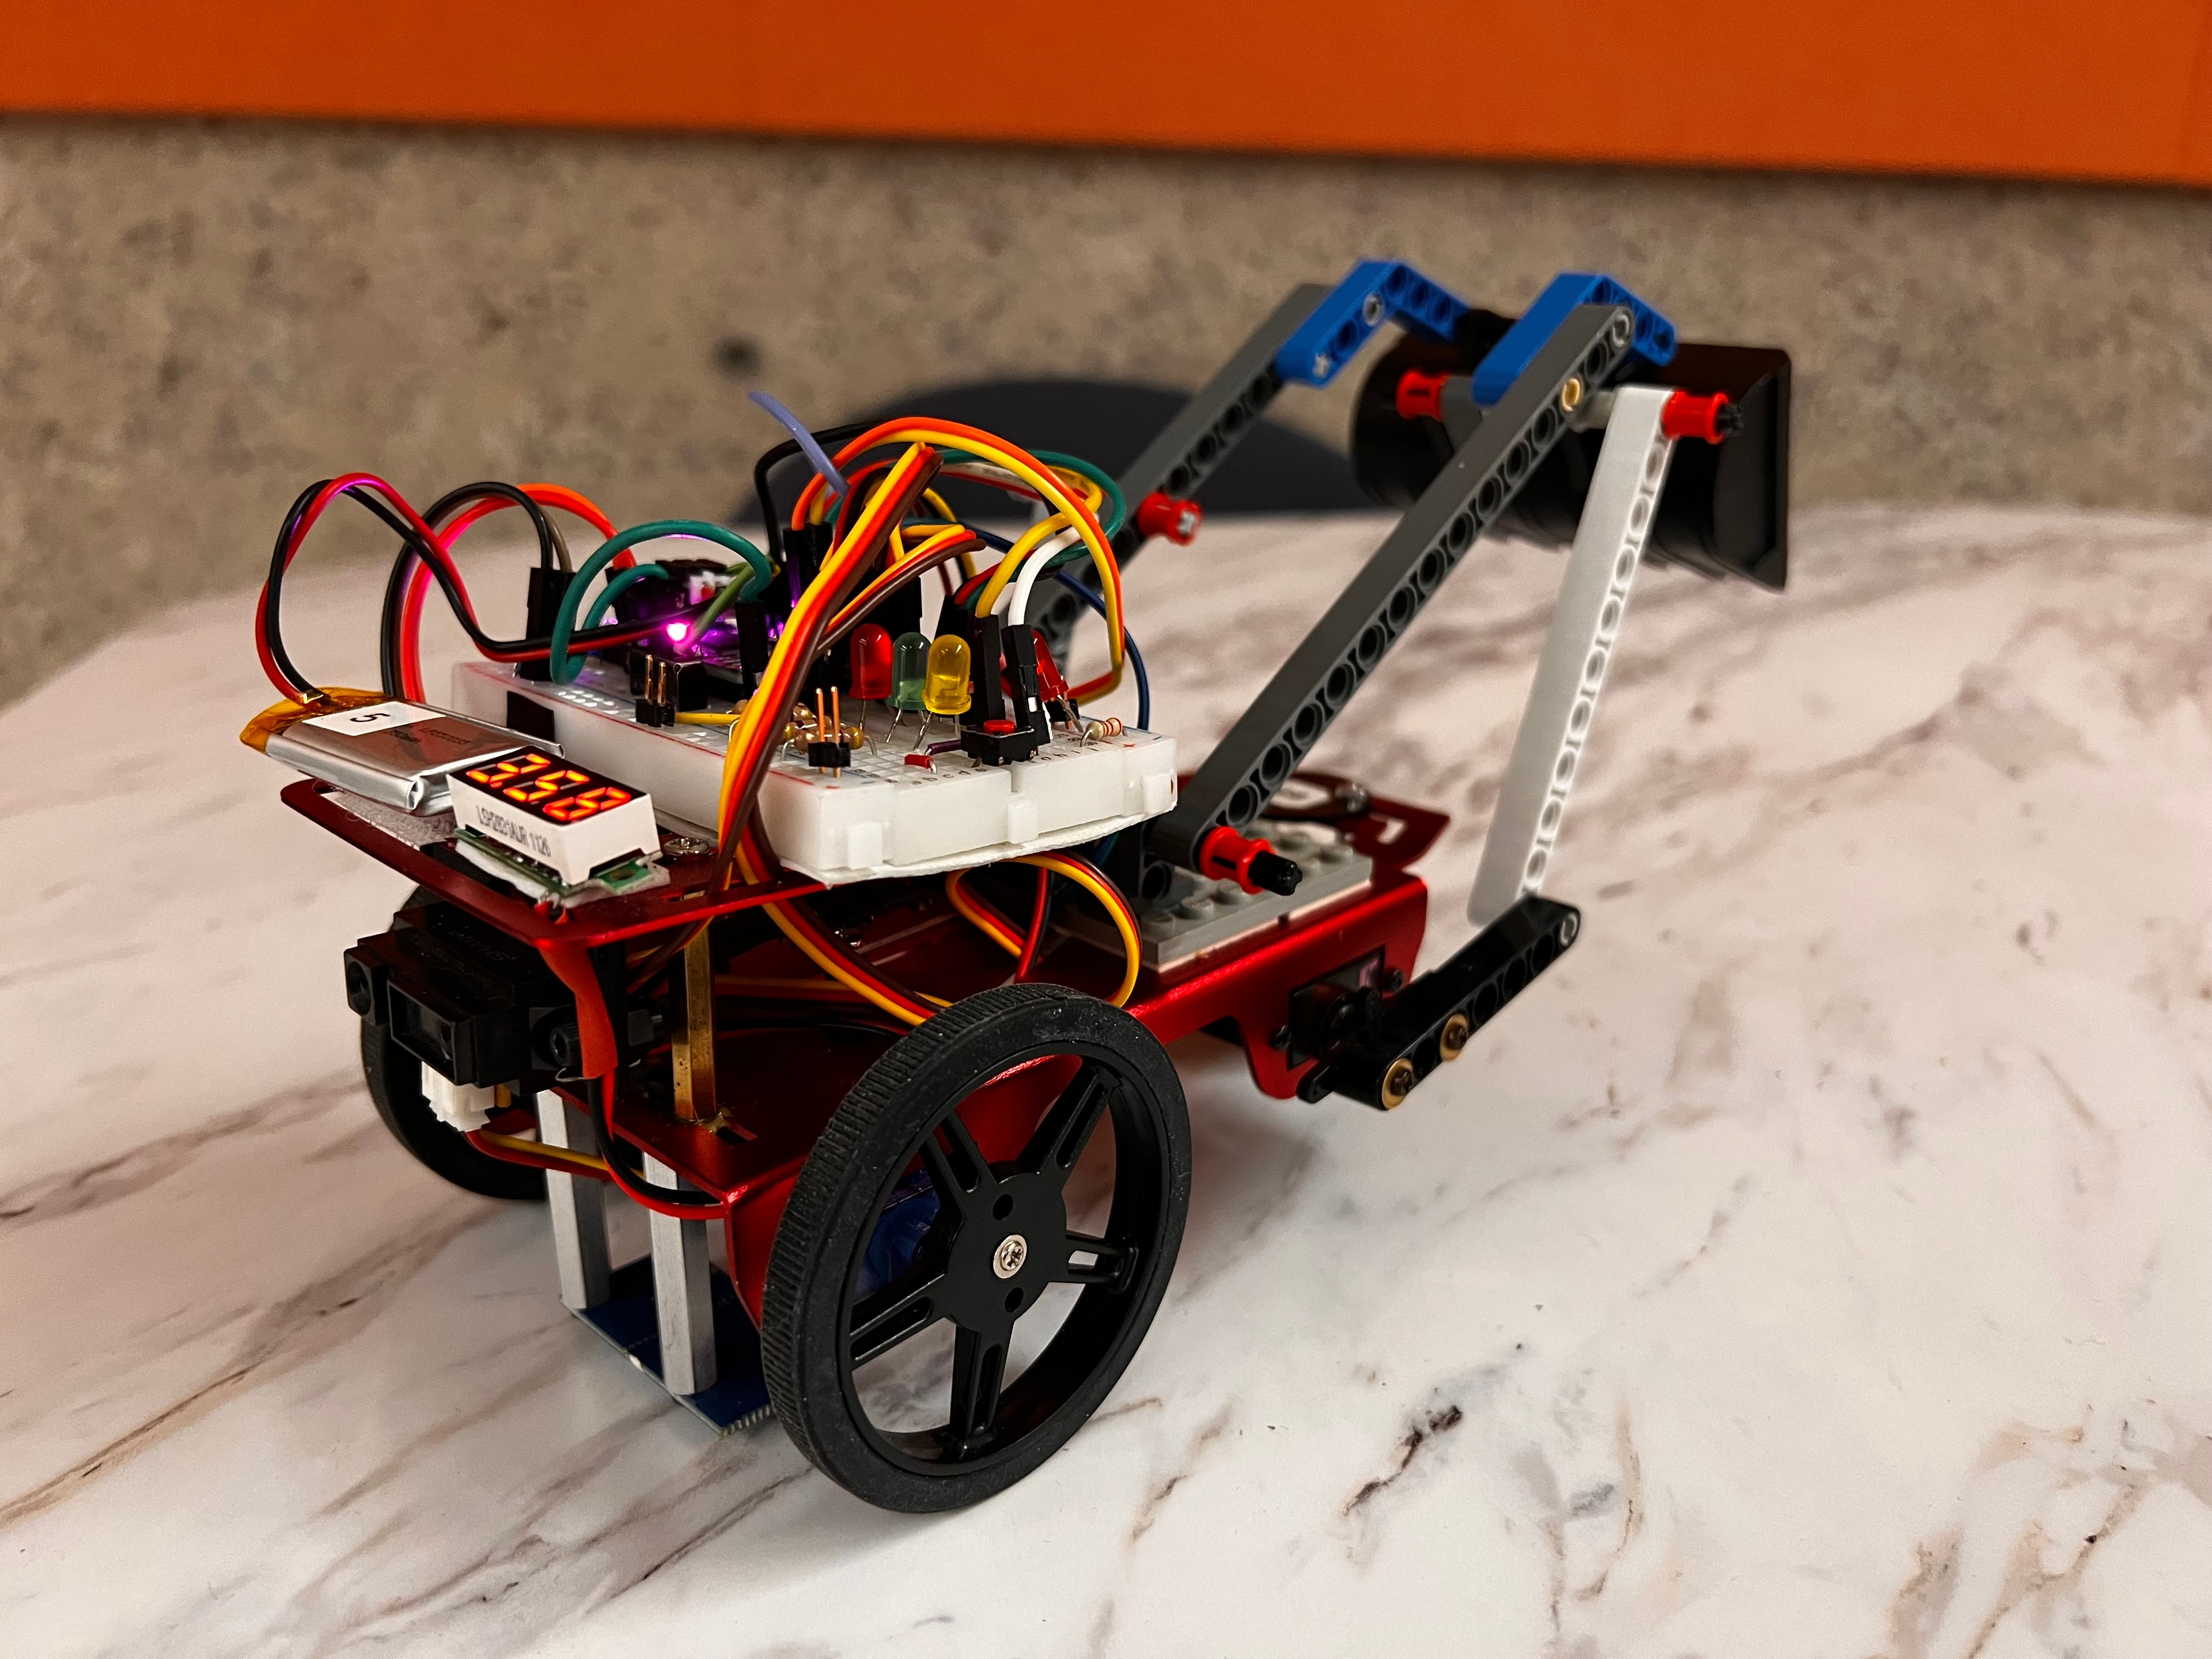
Programmed an autonomous line follower robot that was able to independently traverse a test arena while picking up and transporting plastic wire caps using a scoop. The project included the use of Arduino in C++. The robot moved using 2 servo motors while the scoop was powered by a separate servo. A LIDAR detector was used to find walls and indicate when to turn. 2 photoresistors were responsible for line following. As a result, I was able to create a working prototype that completed its assigned tasks.
Tech stack
ArduinoC++
 1 / 2