Lane Segmentation for Autonomous Navigation
Overview
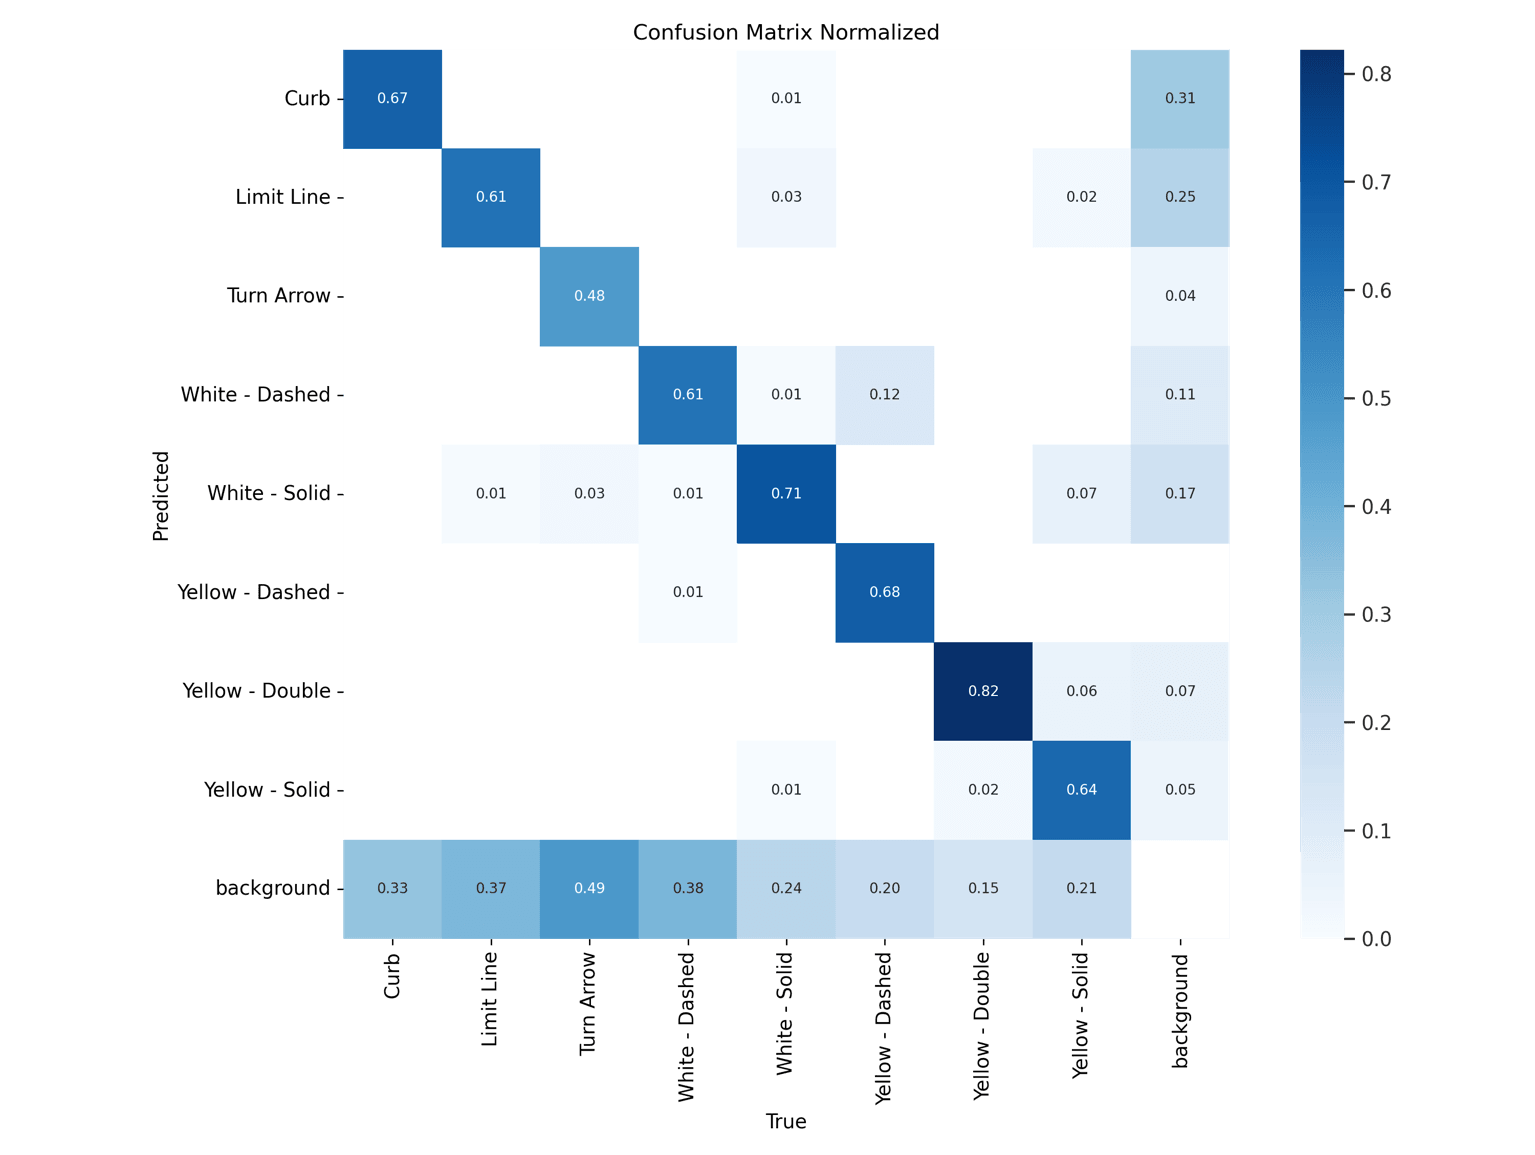
As project lead for the lane detection module of an autonomous vehicle in the GM-SAE AutoDrive Challenge II, I trained a custom YOLOv11 segmentation model in PyTorch on an NVIDIA Blackwell GPU cluster, reaching 83% mAP50 with under 25ms inference latency. The model learned from 50,000+ images labeled over many 'annotation nights', and I audited the annotations of 30+ contributors to keep the dataset consistent. I also wrote a Python automation script using NumPy, Pandas, and the OpenAI API to convert industry datasets into standardized YOLO format, saving 40+ hours of manual conversion, and oversaw a bird's-eye view transformation and the algorithms that calculate the vehicle's position relative to the lane center for the navigation stack.
Tech stack
PythonPyTorchYOLOOpenCVRoboflowROS2
 1 / 3